Efficient event-based semantic segmentation via exploiting frame-event fusion: A hybrid neural network approach
Abstract
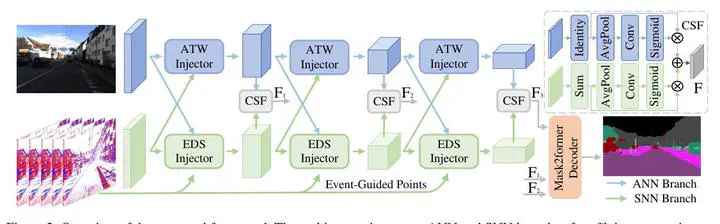
Event cameras have recently been introduced into image semantic segmentation, owing to their high temporal resolution and other advantageous properties. However, existing event-based semantic segmentation methods often fail to fully exploit the complementary information provided by frames and events, resulting in complex training strategies and increased computational costs. To address these challenges, we propose an efficient hybrid framework for image semantic segmentation, comprising a Spiking Neural Network branch for events and an Artificial Neural Network branch for frames. Specifically, we introduce three specialized modules to facilitate the interaction between these two branches: the Adaptive Temporal Weighting (ATW) Injector, the Event-Driven Sparse (EDS) Injector, and the Channel Selection Fusion (CSF) module. The ATW Injector dynamically integrates temporal features from event data into frame features, enhancing segmentation accuracy by leveraging critical dynamic temporal information. The EDS Injector effectively combines sparse event data with rich frame features, ensuring precise alignment of temporal and spatial information. The CSF module selectively merges these features to optimize segmentation performance. Experimental results demonstrate that our framework not only achieves state-of-the-art accuracy across the DDD17-Seg, DSEC-Semantic, and M3ED-Semantic datasets but also significantly reduces energy consumption, achieving a 63% reduction on the DSEC-Semantic dataset. The code and dataset will be made publicly available.
本文提出一种高效的混合神经网络框架,用于事件相机语义分割。该框架包含处理事件流的脉冲神经网络(SNN)分支和处理帧图像的人工神经网络(ANN)分支,并设计了自适应时间加权(ATW)注入器、事件驱动稀疏(EDS)注入器和通道选择融合(CSF)模块,以充分融合帧与事件的互补时空信息。在DDD17-Seg、DSEC-Semantic和M3ED-Semantic数据集上取得了最先进精度,并在DSEC-Semantic上降低63%能耗。